Cameras
FPV, mapping and thermal cameras — streamed, controlled and captured from, with imaging parameters exposed rather than fixed.
The categories below describe what the platform works with and what it does with each — stream it, diagnose it, control it. For a specific model, ask: the answer is often yes, and where it is not, integration is a defined path.
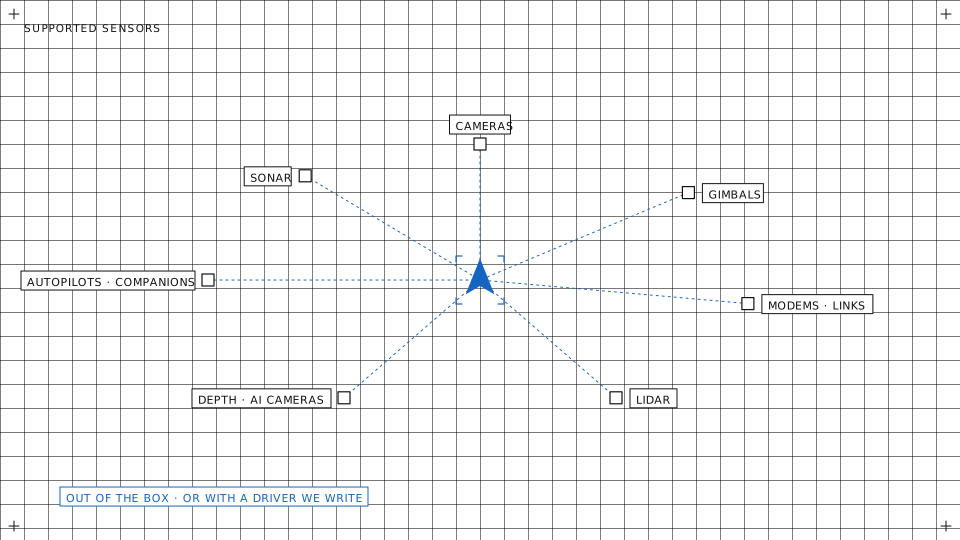
Each entry is characterised by its interface and what the platform does with it.
FPV, mapping and thermal cameras — streamed, controlled and captured from, with imaging parameters exposed rather than fixed.
Pointing control with angle read-back, so aiming is a command with a confirmation rather than an open-loop nudge.
Connectivity hardware monitored as a first-class device, because link health explains more incidents than anything else.
Ranging and mapping sensors, including their use in the navigation stack rather than only as a payload.
Devices such as the OAK-D Lite that carry their own inference, used as the reference platform for edge AI.
MAVLink flight stacks and the companion computers alongside them, which is where the onboard client runs.
Sonar on the fly page · the waterfall and the swath of a surface vessel, live
A published model-by-model compatibility matrix goes stale faster than it can be maintained, and a stale matrix is worse than none — it produces confident answers that are wrong. We would rather answer your specific question against the current state of the platform.
Devices connect over the usual interfaces — USB, Ethernet, CAN and UART — and adding a peripheral that is not yet supported is a documented extension path through Skyclient rather than bespoke work on our side. Tell us the model and the interface and we will tell you where it stands.
Send the model and interface, and we will confirm what is supported today.