Mixed hardware
DJI docks next to ArduPilot airframes, rovers and boats.
The operations stack you deploy for every client: drones, docks, rovers and boats, simulated, automated and run from one console. Stop rebuilding the plumbing for each project and sell the solution on top.
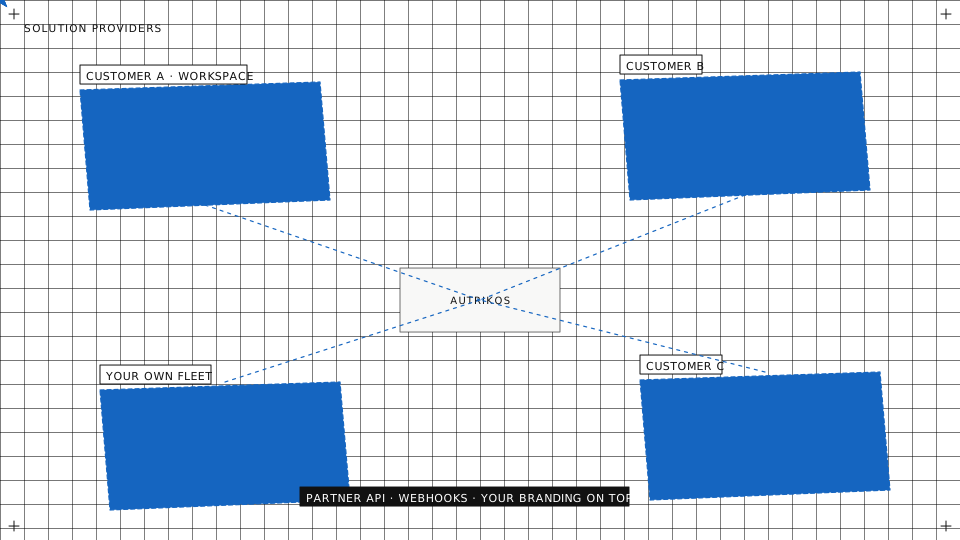
You deliver the solution. Today you also rebuild the operations layer, project after project.
DJI docks next to ArduPilot airframes, rovers and boats.
OEM clouds only run their own devices.
Video, telemetry, logs and maps, re-integrated for each client.
Work stops at handover, with nothing left running for the client.
One console and one data model across vendors and vehicle types, over MAVLink, DJI MSDK v5, DJI Cloud API and PSDK.
DJI enterprise via MSDK v5 and Cloud API; any ArduPilot or PX4 airframe.
DJI Dock 1, 2 and 3: unattended, scheduled and alarm-triggered.
ArduPilot rovers and UGVs on the same map.
Unmanned surface vessels with sonar and echo sounders.
Two integration paths, both shipping.
Dock 3 (M4D/M4TD), Dock 2 (M3D/M3TD), Dock 1 (M30/M30T), RC Plus 2 (M4E/M4T, Matrice 400) and RC Pro Enterprise (M3E/M3T/M3TA) connect to the platform directly.
Matrice 400, M350 RTK, M300 RTK, Matrice 4E/4T and 4D/4TD, Matrice 30/30T, Mavic 3E/3T, Mini 4 Pro and Mini 3 / 3 Pro, with the app on the controller as the gateway.
Build automations visually, then watch every run live on the same canvas. For example: perimeter alarm → weather and battery check → operator confirms → dock launches → stream and notify.
Schedules, telemetry, device state, mission completion, geofence breaches and more start a workflow.
Every run checks its conditions before a robot moves.
Human sign-off where it matters, and workflows that start other workflows.
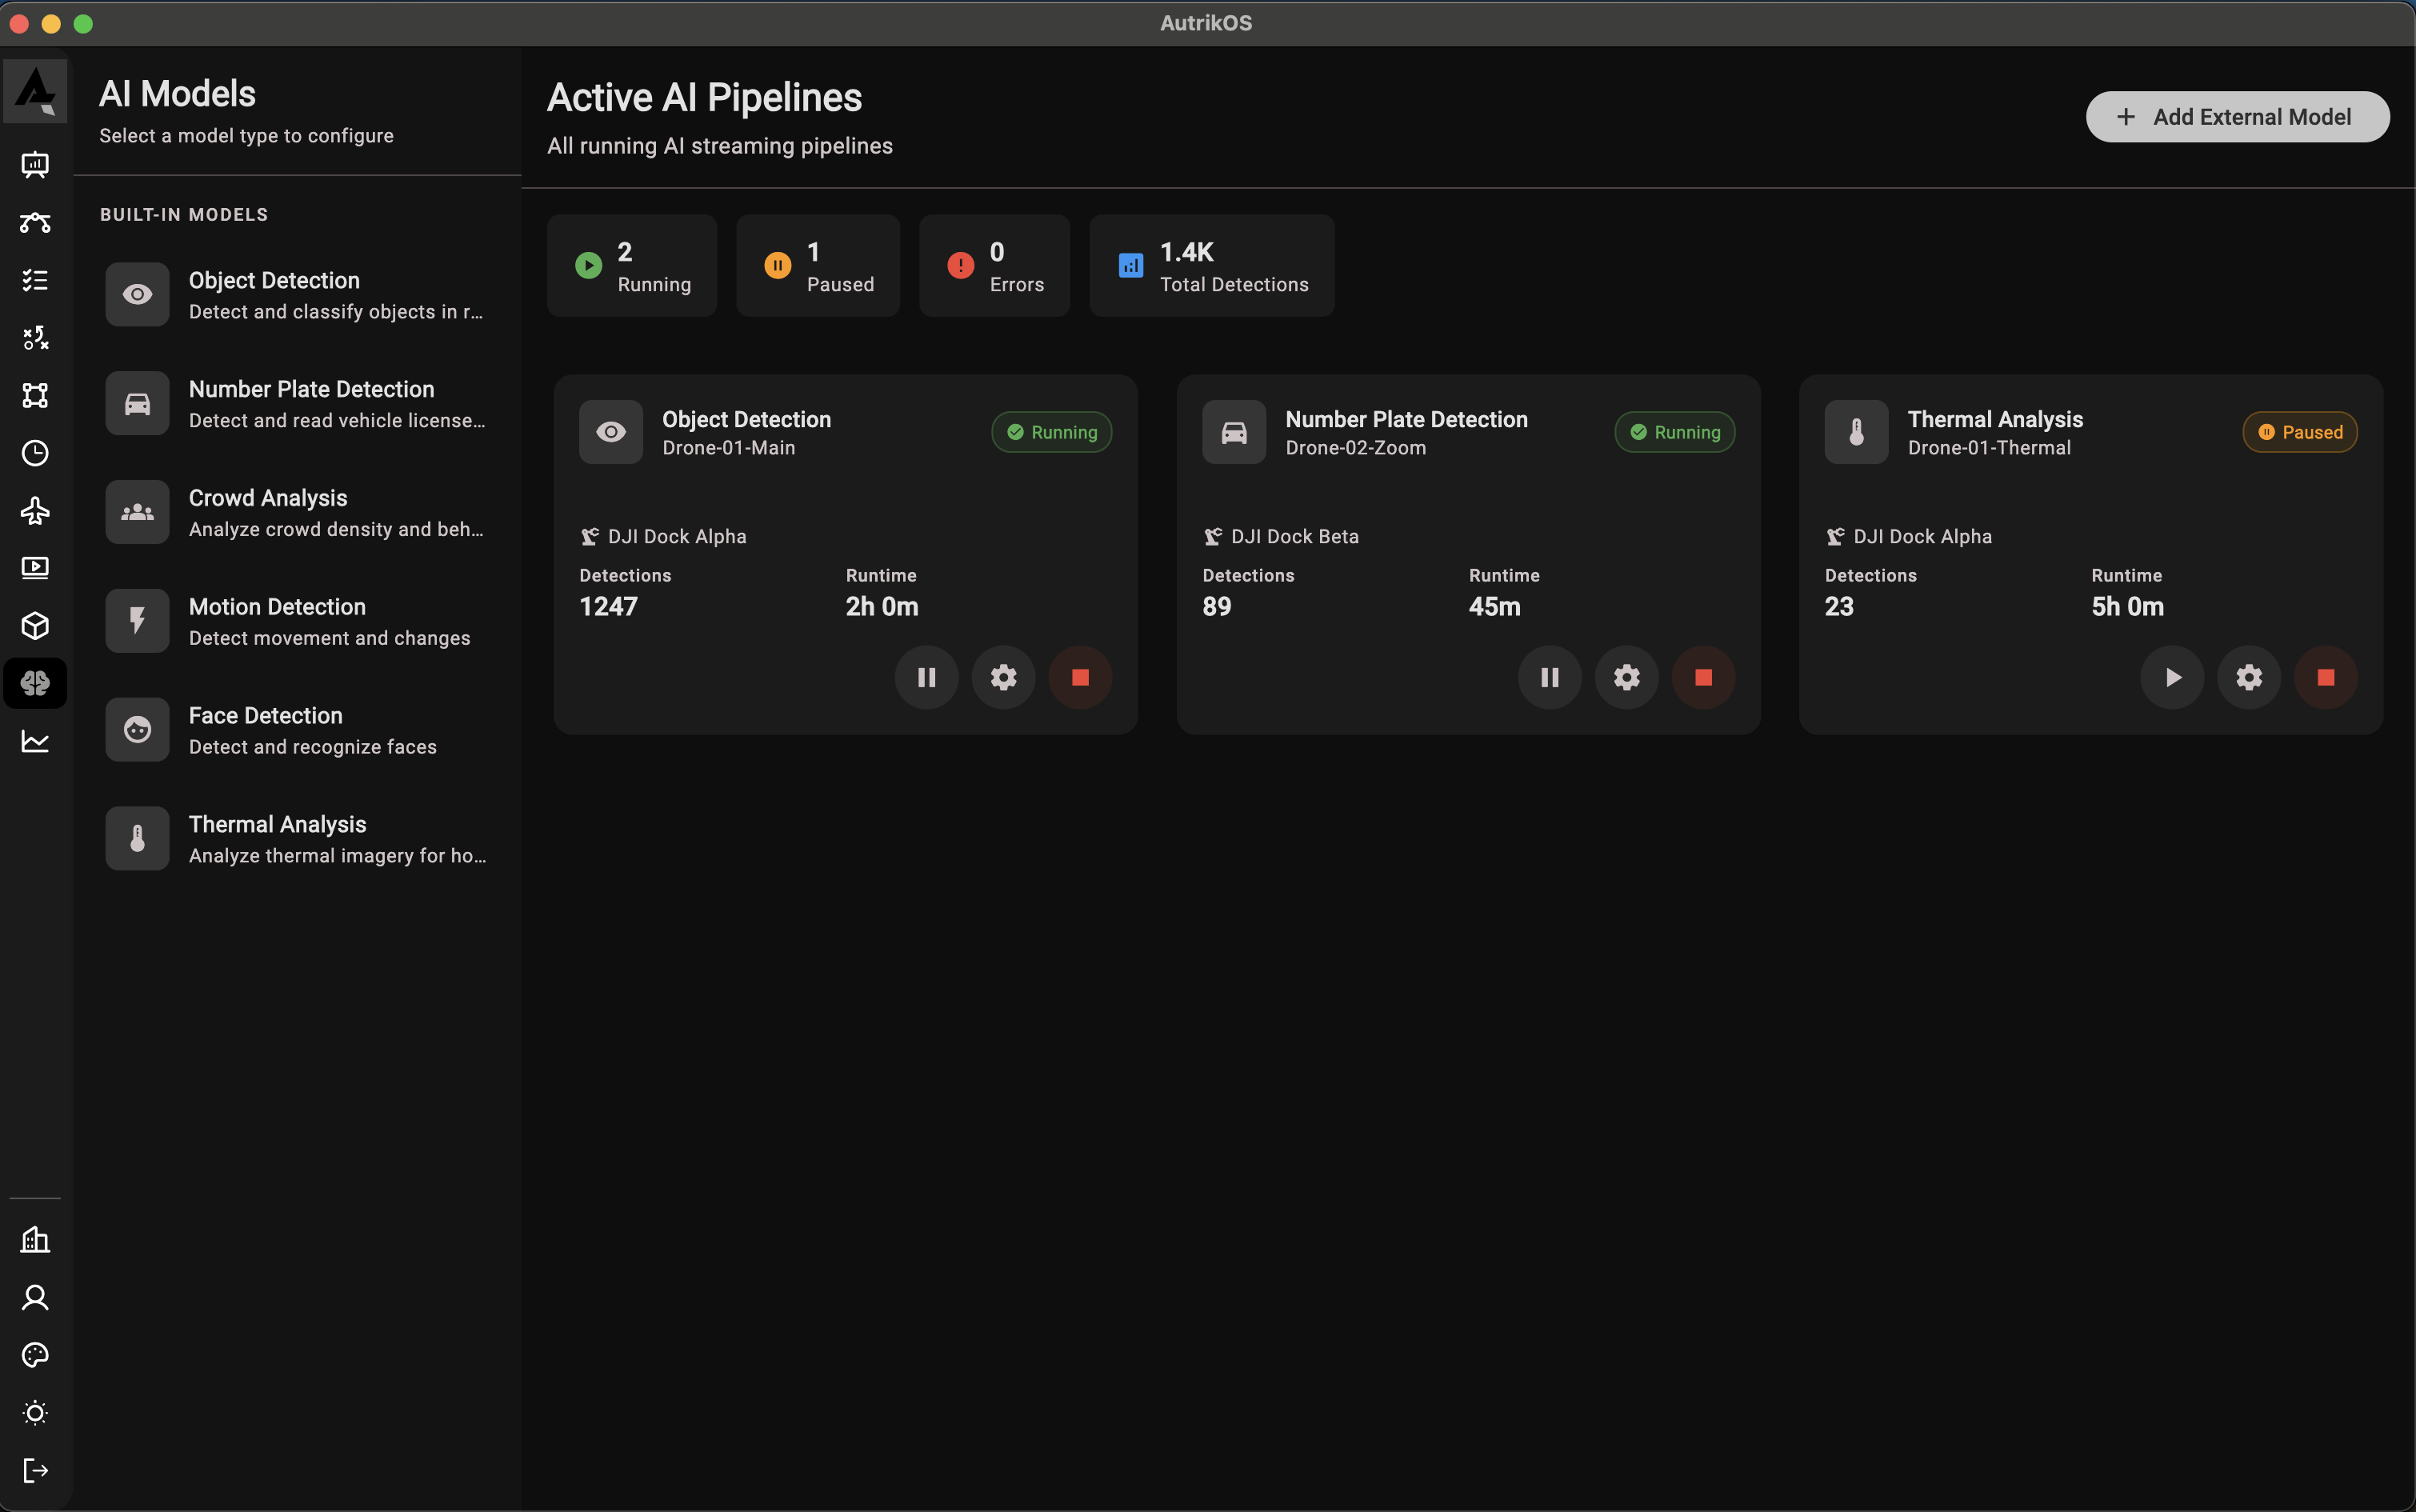
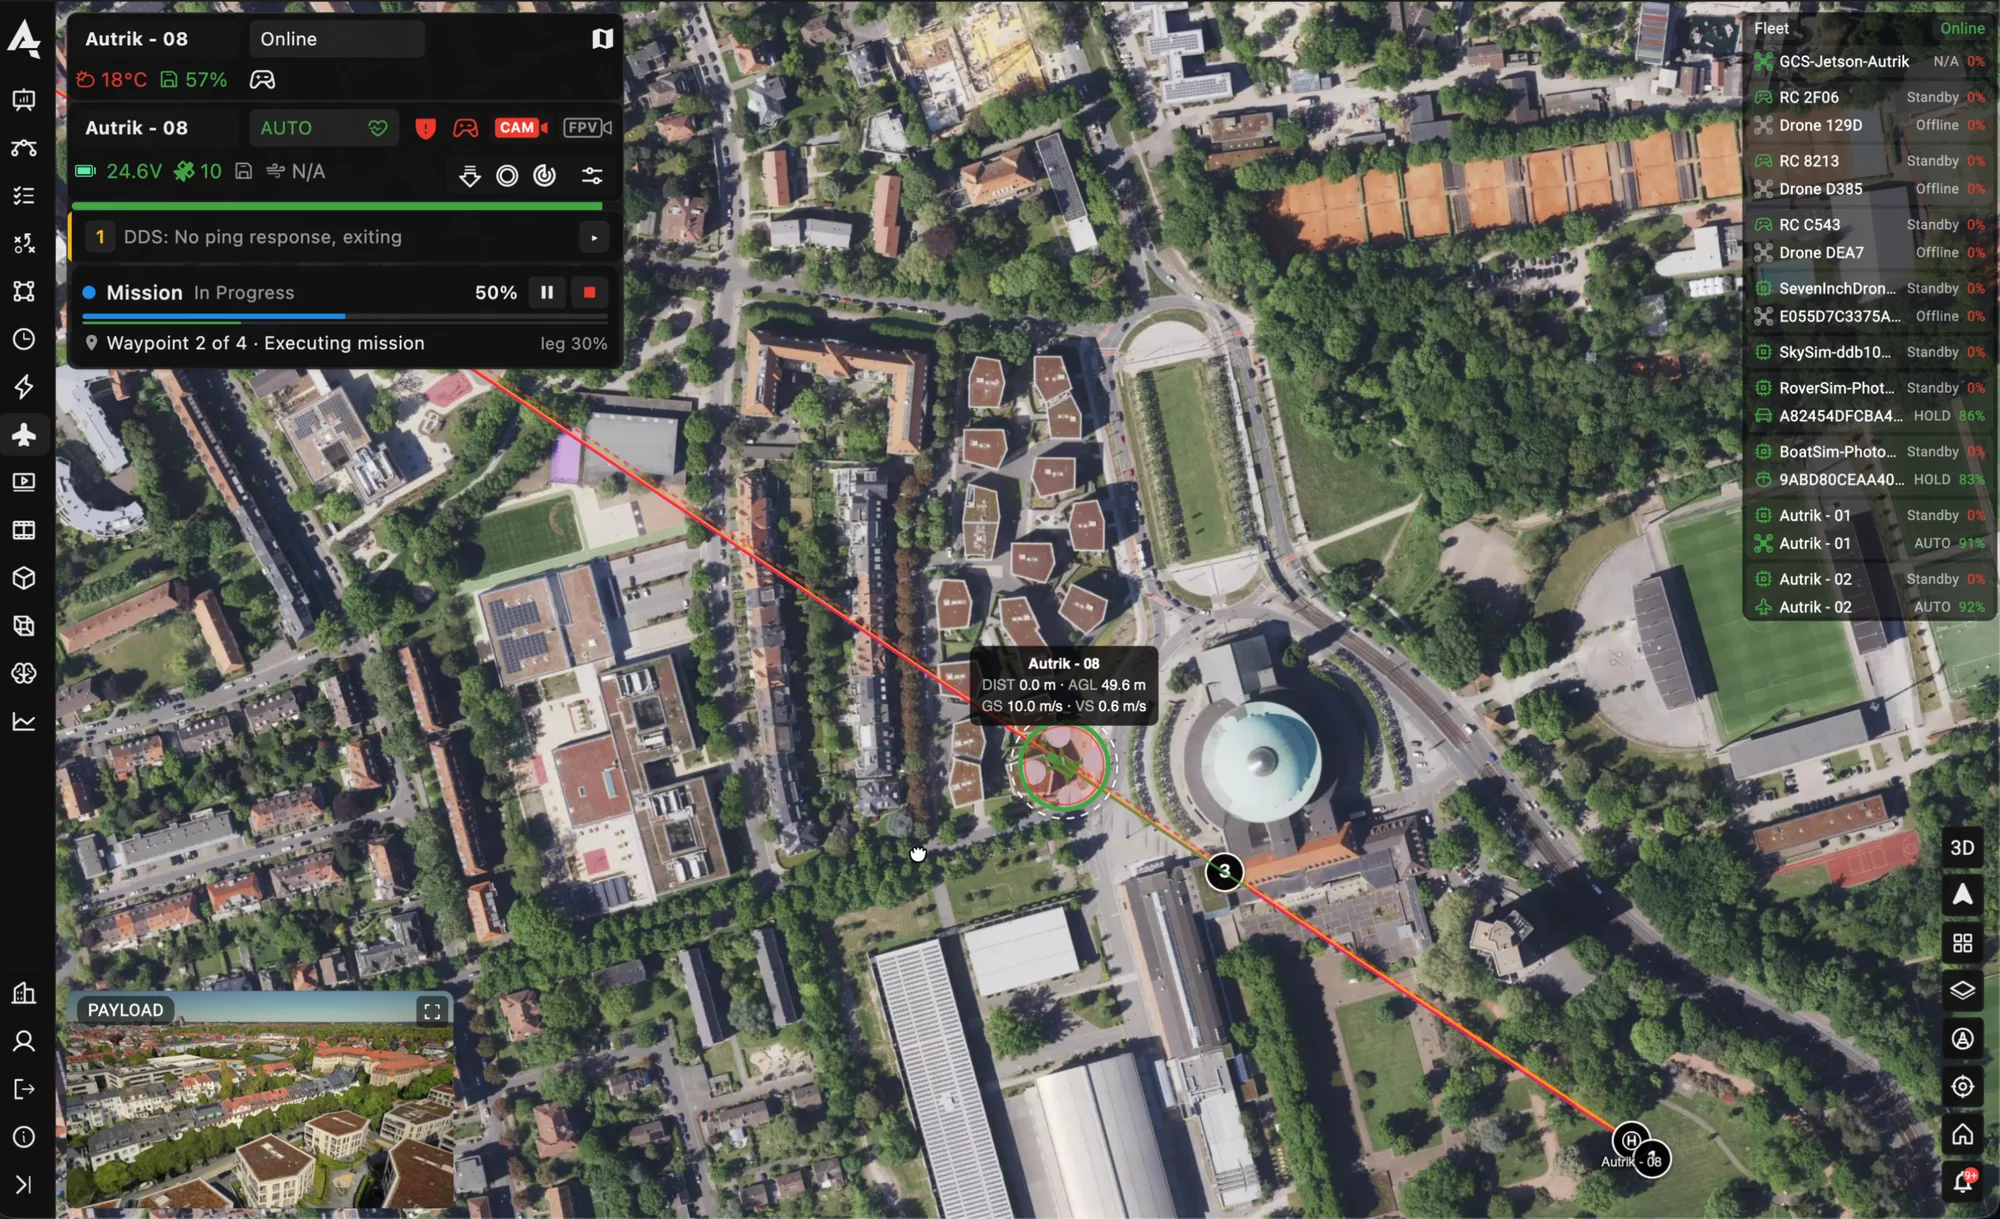
The drone launches to the incident; AI recognises and tracks people and vehicles live for the dispatcher.
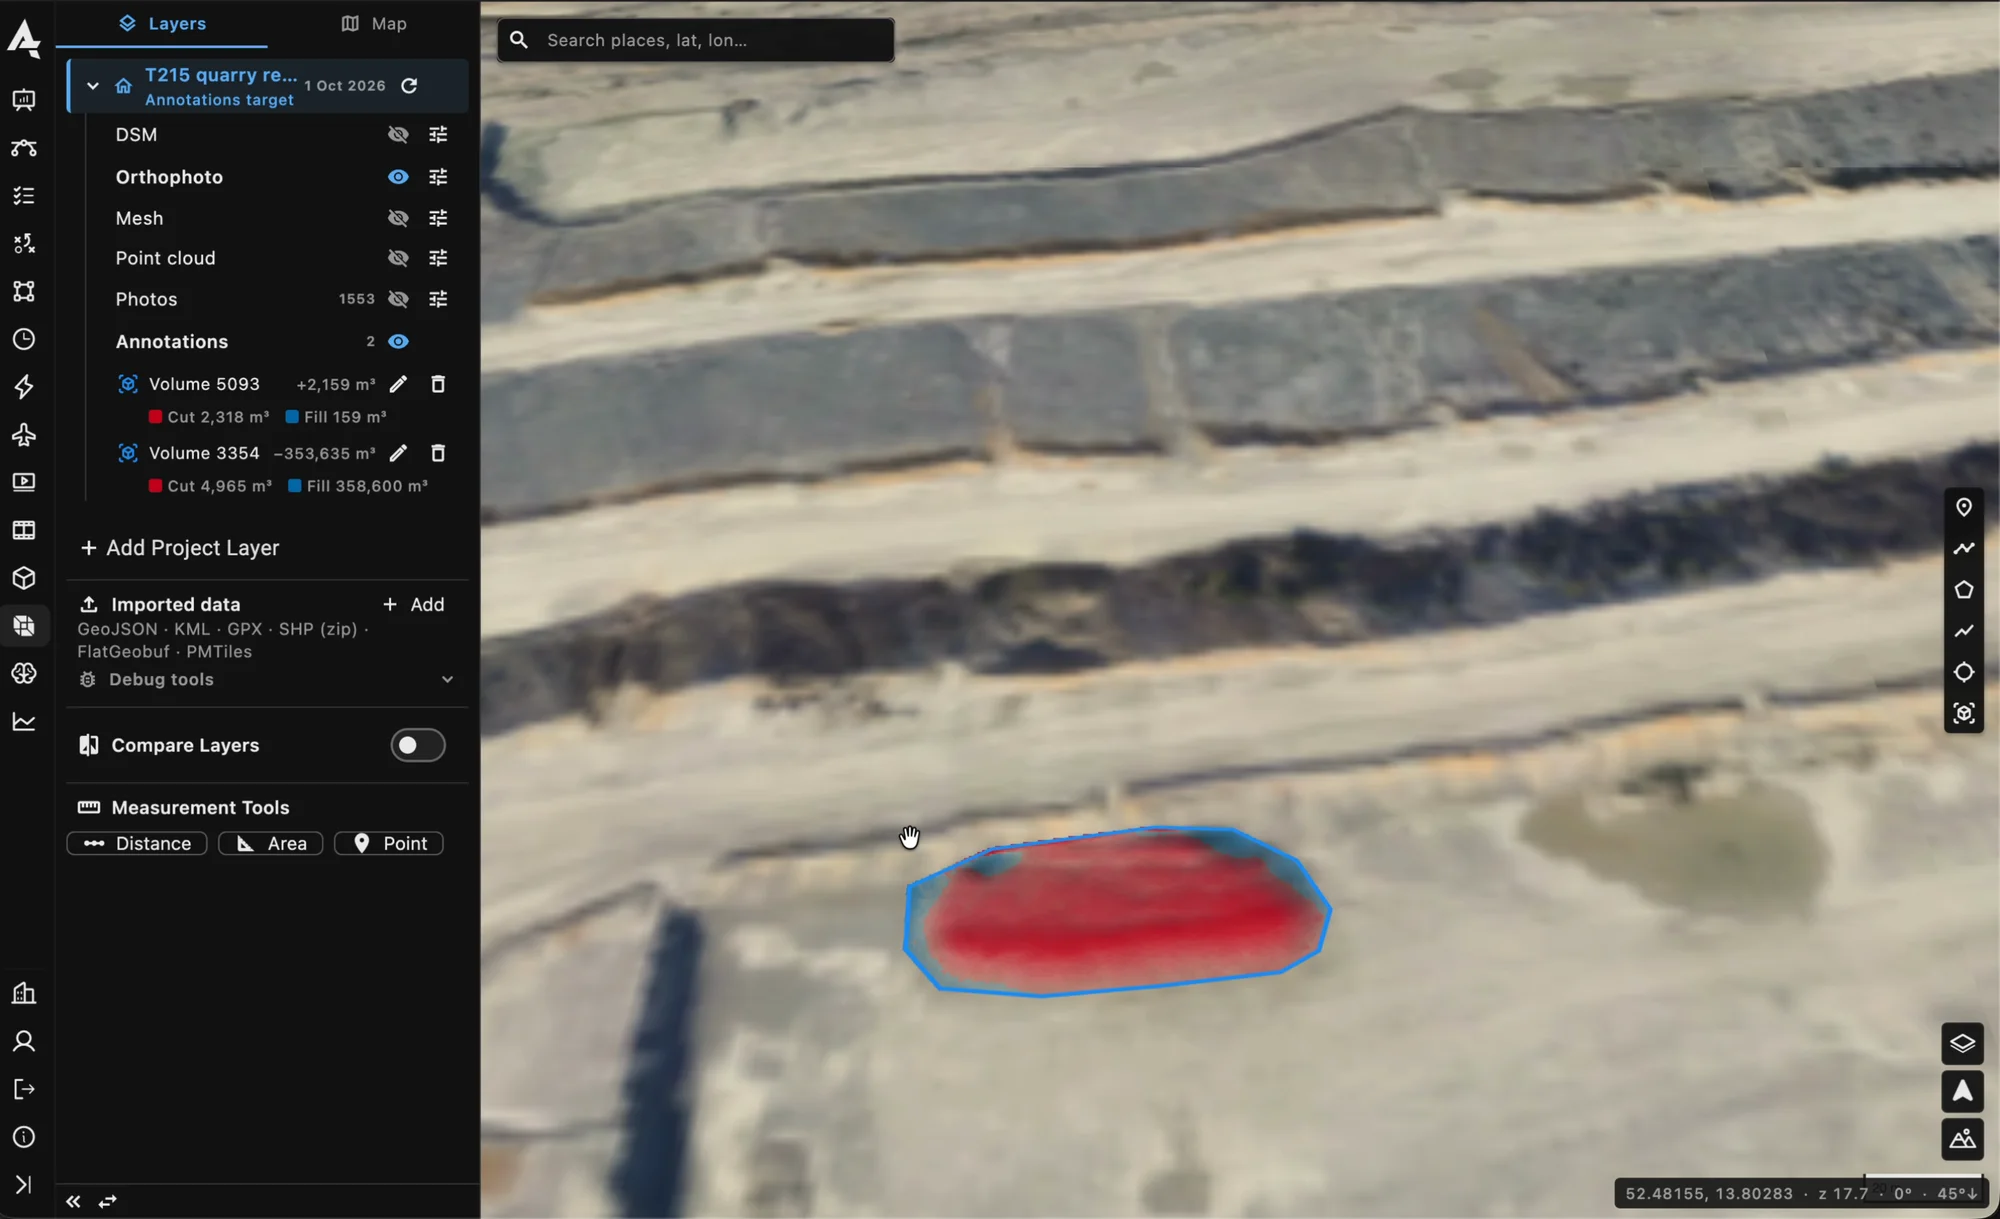
Scheduled capture flights, automatic processing and progress compared layer by layer, shared with the client.
An alarm triggers the flight: the dock launches, flies to the alarm point and streams to the control room.
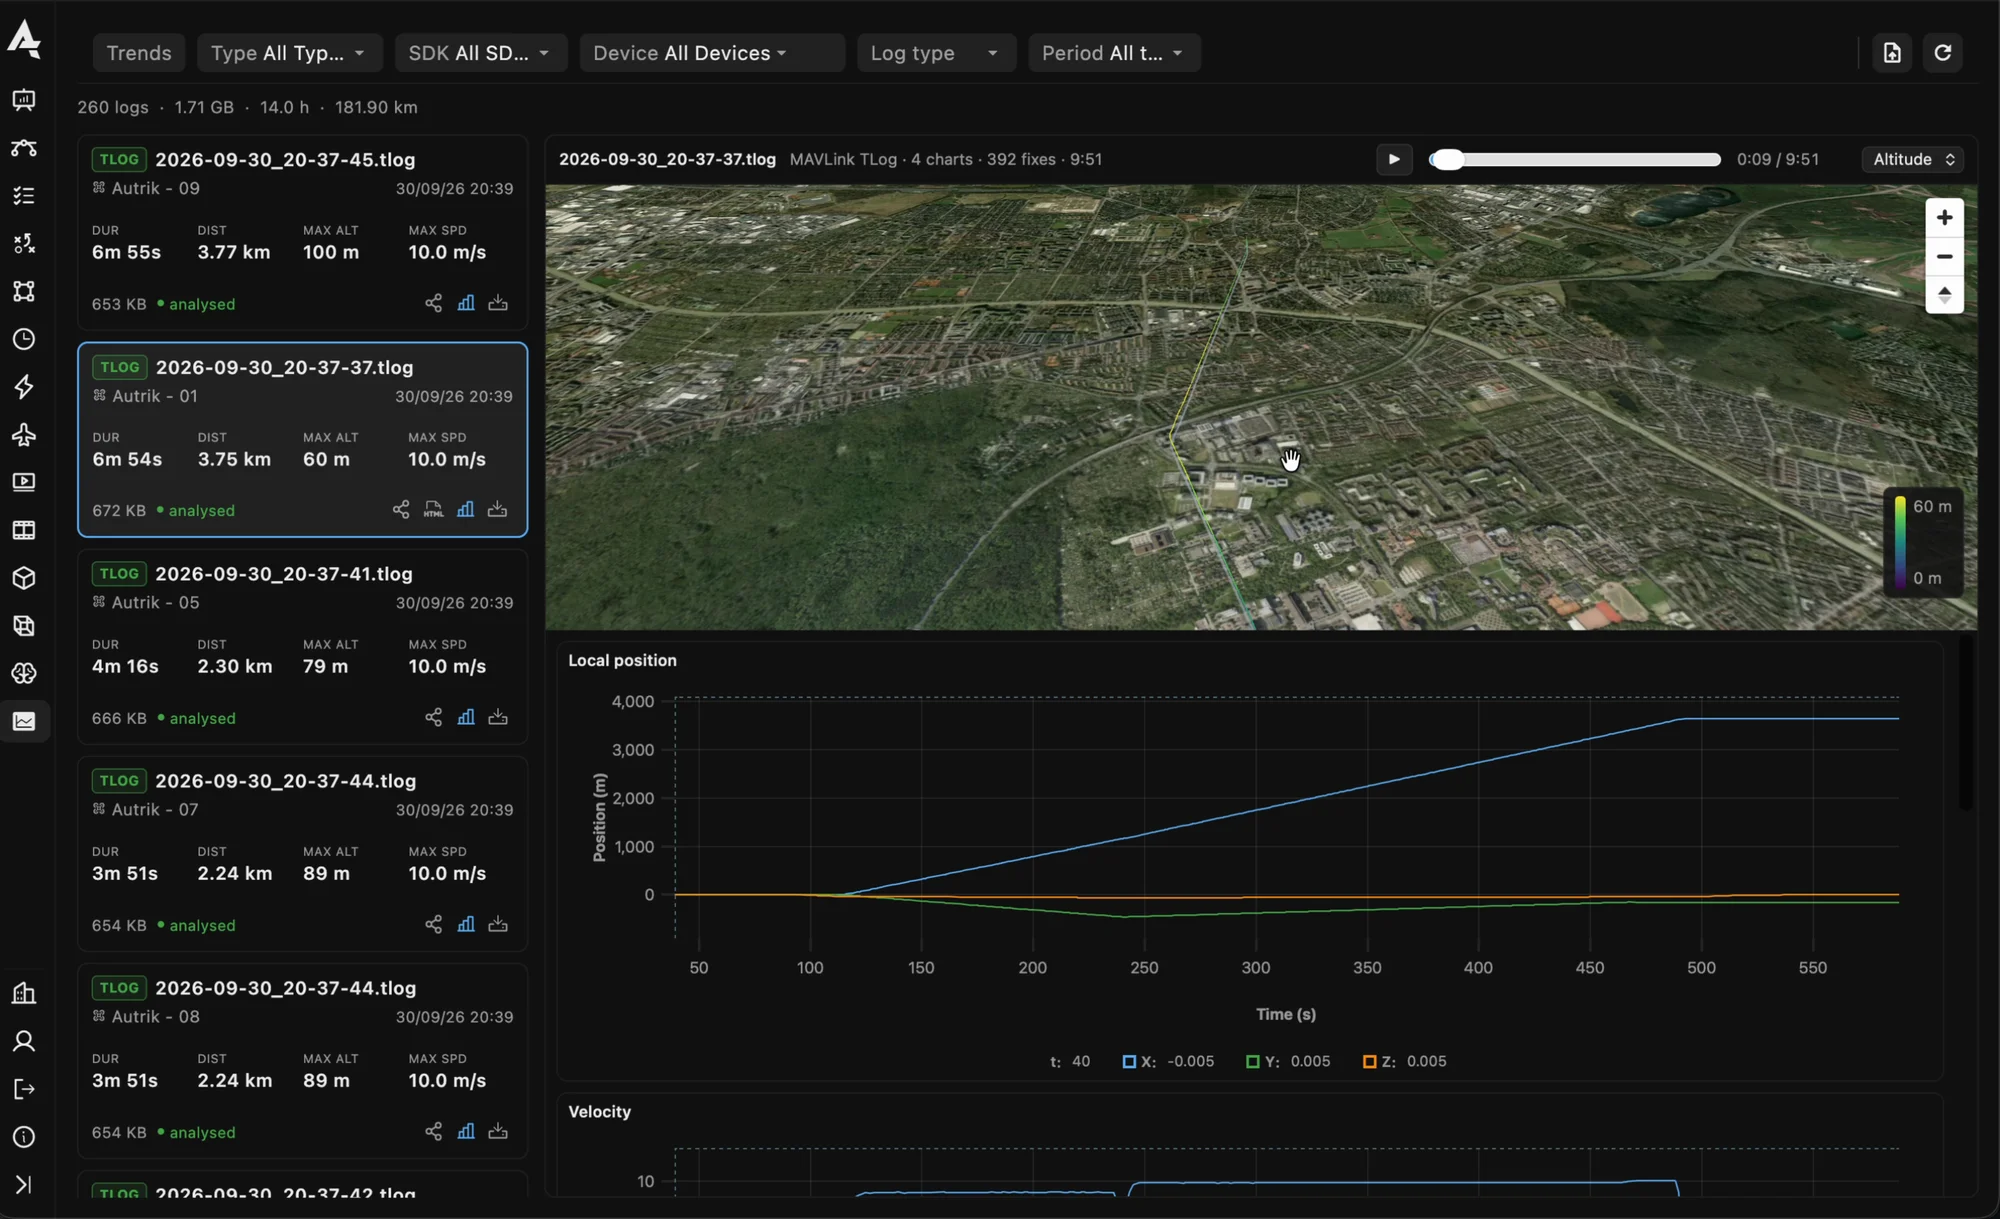
Scheduled flights over plants and pipelines with gas sensors; readings logged, trended and flagged.
Simulated 3D worlds built from real places, for operator training and for training machine-learning models.
Our EU cloud, your cloud region, on-prem or air-gapped. Same software.
APIs, MQTT events and share links connect your client systems.
Deployed with a major telecom operator (DFR, forest-fire prevention).
We set up the stack, twin the site and train your team.