· Autrik Team· News· 2 min read
Welcome to the Autrik Blog
Stay updated with the latest news, insights, and developments in automated drone operations and fleet management.
Welcome to the Autrik blog. This is where we write about what we build, what we fly, and what we learn doing both: the operating system for drone and robot operations, and the people who run fleets on it.
What to expect
- What we learned flying. Field notes from inspection, mapping and public-safety work: which camera to map with, when a cheap aircraft is enough, what a boat does that an aircraft does not.
- How the platform works. The engineering behind AutrikOS: the stack and why it is shaped that way, flying without GPS, how a fleet’s health is judged every night.
- Operations, honestly. Why fleets are still the exception, what a DFR programme needs before the first call, drones and CCTV in one security workflow.
- Company notes. Why we are bootstrapped and publicly funded at the same time, what we took from space, and the news when there is some.
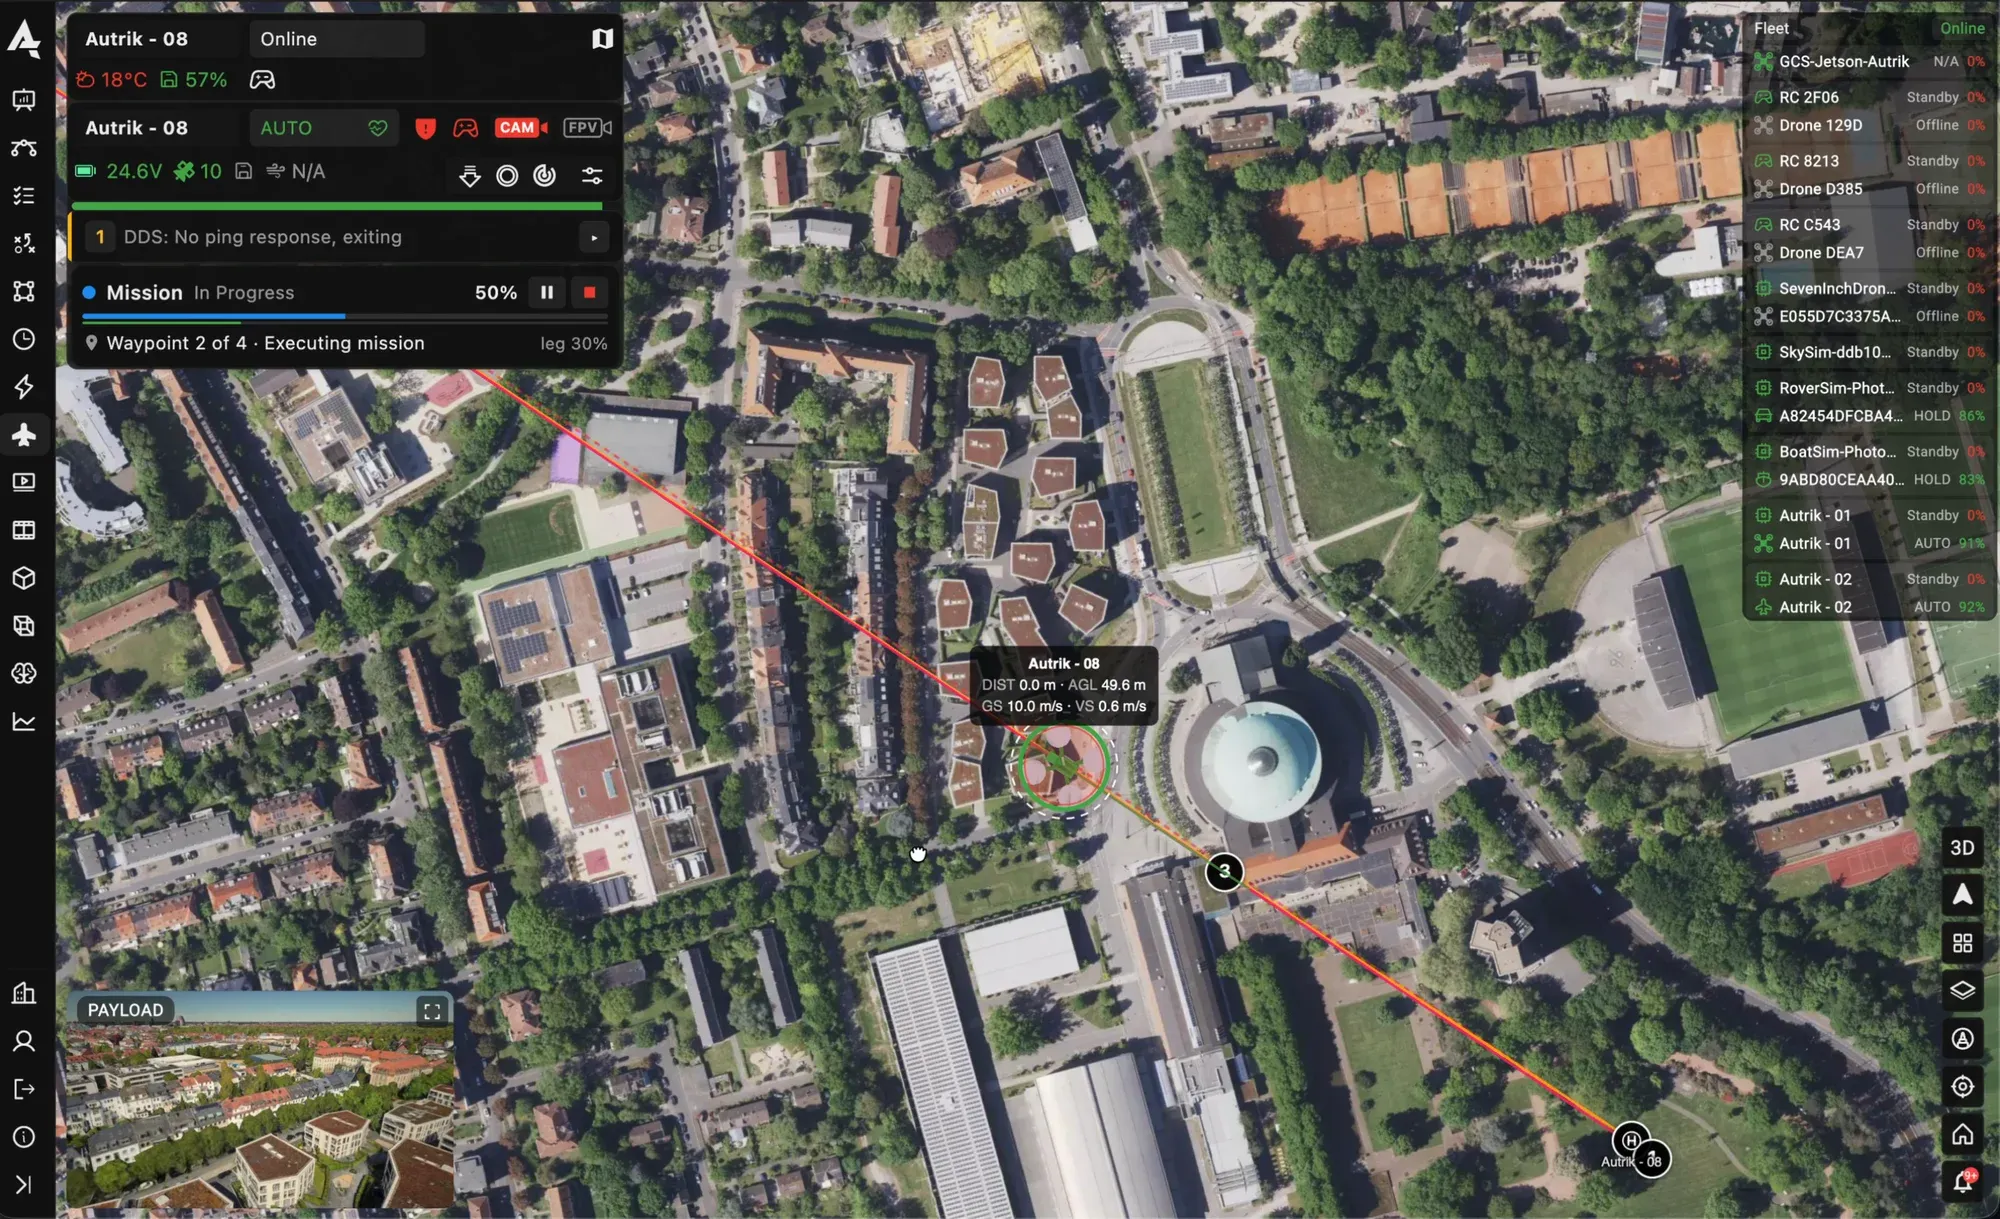
The fly page: an aircraft on a mission, its telemetry and the fleet list.
What we build
AutrikOS is one console for every vehicle an operation runs: aircraft on open autopilots or DJI, docks, rovers and boats. Plan a flight on the map, fly it or schedule it from a dock, watch every camera on one wall, turn the photos into maps and models, keep every flight’s log and every aircraft’s health, and prove all of it to an auditor. The features are each described on their own page, and the changelog says what shipped when.
How we write
Short, concrete, and honest about where things stand. When a post describes a capability, it is one you can use today; when it describes a direction, it says so. Numbers come from our own flights or from sources we name. We do not quote performance figures we have not measured.
Stay connected
Follow us on LinkedIn, join the Discord, or take the newsletter, roughly monthly and worth opening. And if a post raises a question about your own operation, talk to us.